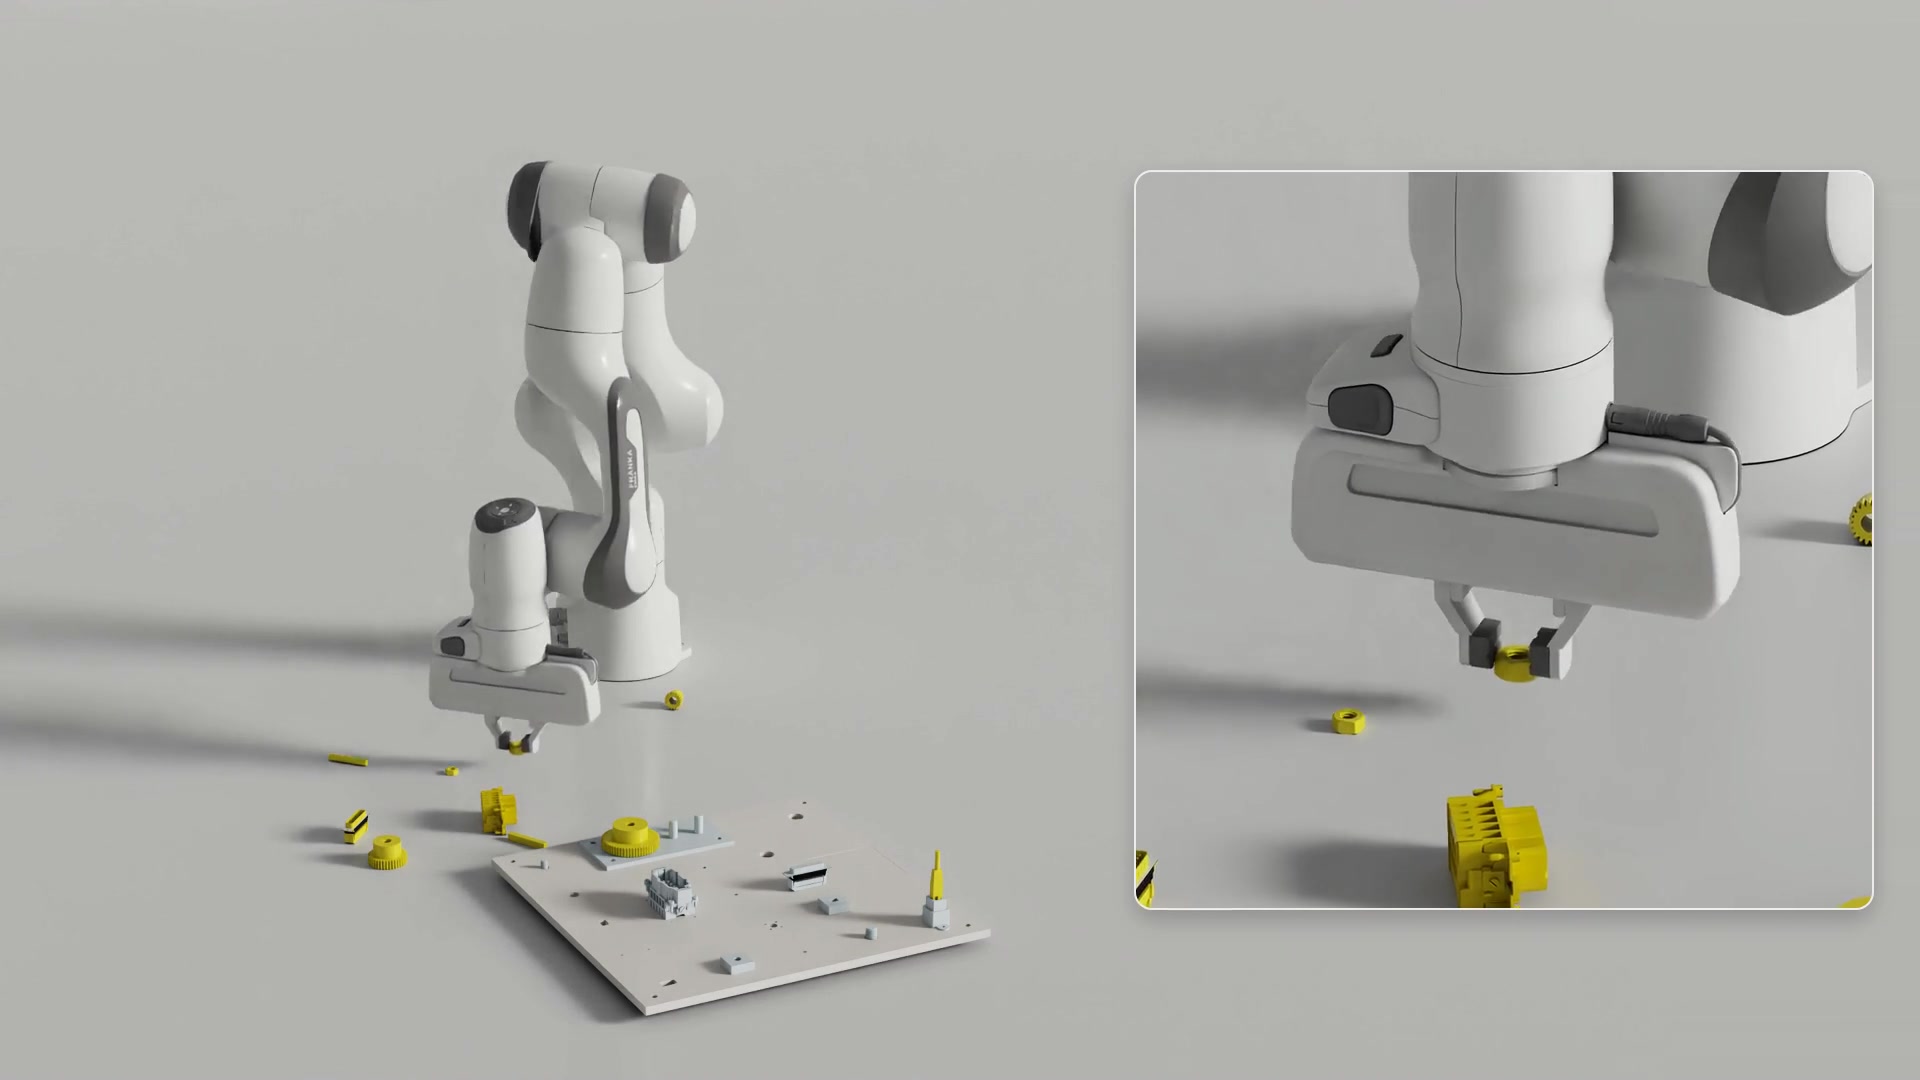
AlphaNIST
Learning dexterity and coordination for robotic assembly in simulation, with binary task rewards and no prescribed manipulation stages.
Summary
A new approach to training robots focuses on developing dexterity and coordination for assembly tasks using simulations that reward binary outcomes, rather than following predefined steps. This method could enhance robotic efficiency and adaptability in complex tasks.
Comments (7 of ) ⌛